Personal · 2023
Locking Mecanum Wheel
Servo-actuated roller constraint for selectable traction
An independent servo-actuated mechanism exploring how a mecanum wheel could preserve omnidirectional motion when unlocked and gain conventional traction when engaged.
- Role
- Designer / Builder
- Organization
- Personal Project
- Focus
- Mechanism Design / Rapid Prototyping
Skills
CADFDM PrintingServo Actuation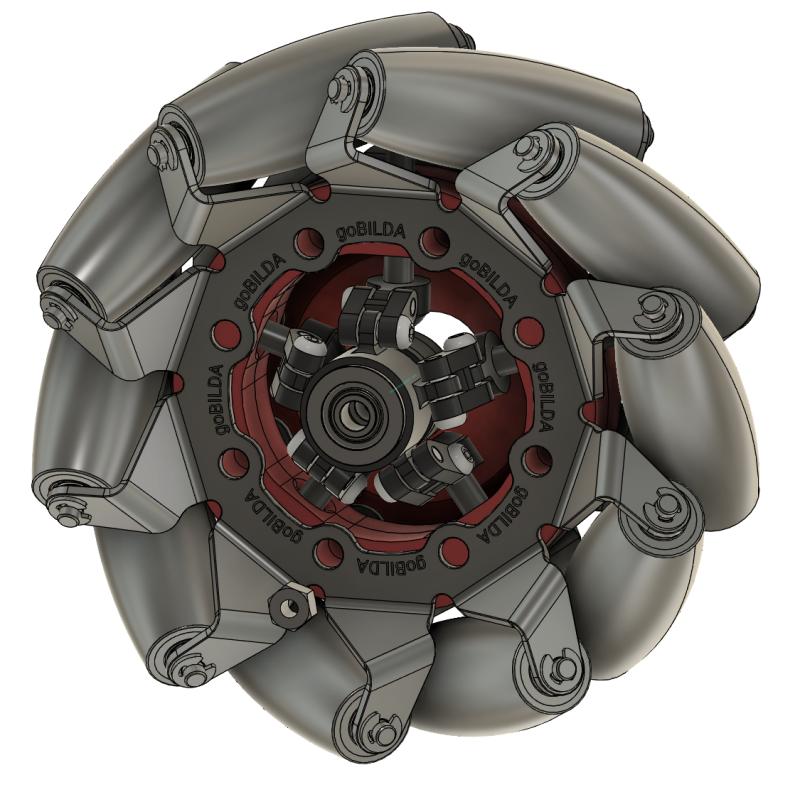
Mobility and traction pull in different directions
Mecanum rollers enable omnidirectional motion, but the same roller freedom can limit straightforward traction. I explored a mechanism that selectively constrains the rollers when conventional forward grip is more useful.
Lock the rollers only when needed
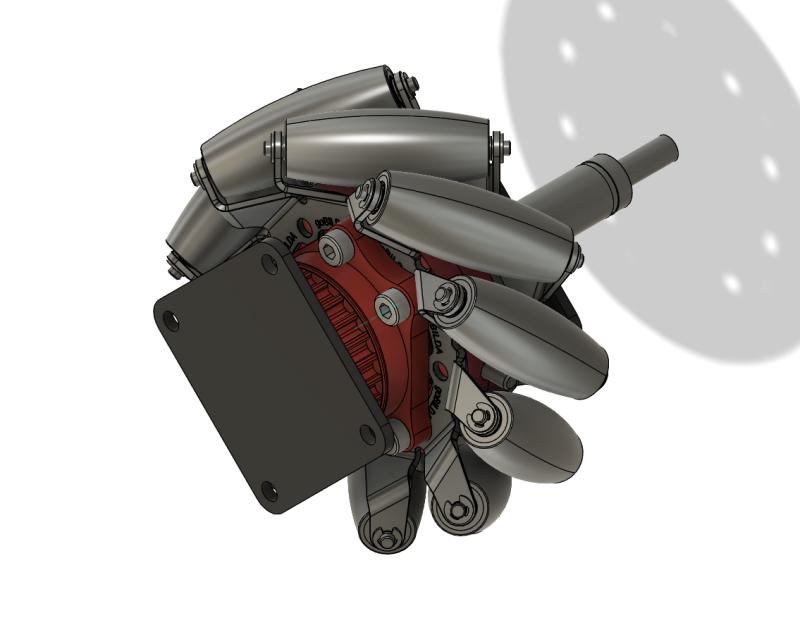
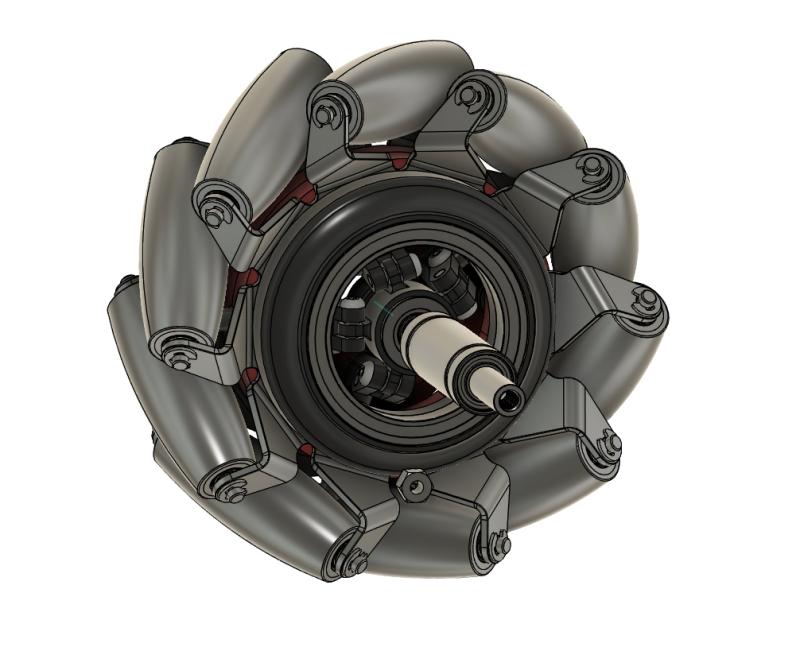
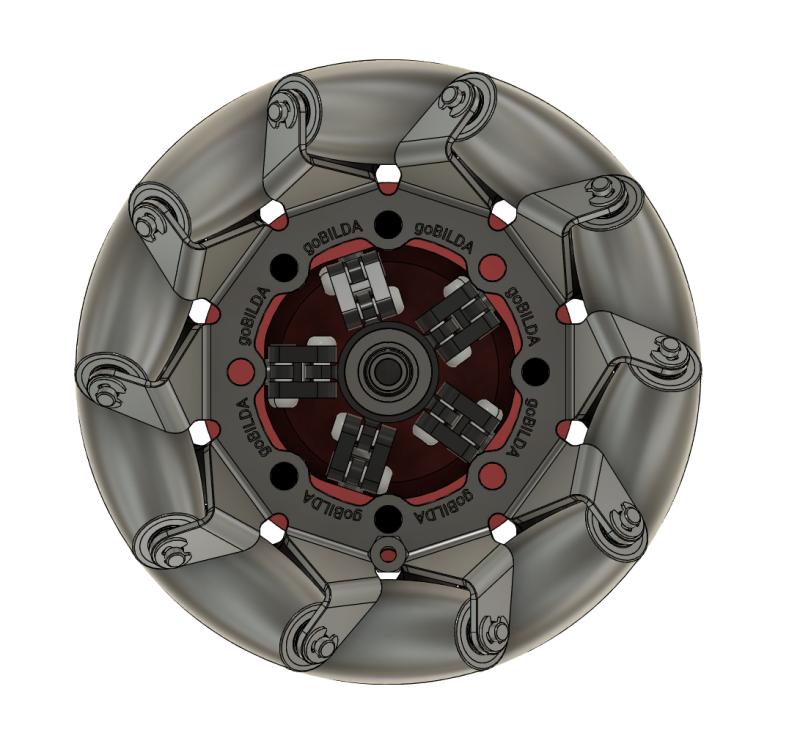
A linear servo drives a linkage housed in 3D-printed components. The engaged mechanism applies force to or constrains the rollers; releasing it returns the wheel to normal mecanum behavior.
- Low-cost, off-the-shelf actuation
- 3D-printable geometry
- Reversible engagement
- Reproducible assembly
What I would test next
The project demonstrated a practical actuation concept and packaging approach. Quantitative traction improvement was not measured, so no performance gain is claimed. A next iteration would instrument wheel load and drawbar force to compare locked and unlocked states.
Tools: CAD · FDM Printing · Servo Actuation